816 posters, 24 topics, 3,314 authors, 1,012 institutions
ePostersLive by SciGen Technologies S.A. All rights reserved.
SAGES 2026 Annual Meeting Emerging Technology Session
March 25-28, 2026 | Tampa, FL, USA
ETP890
Next-Generation Tracked Laparoscopic Ultrasound for Precision Surgery
Poster Presenter
Part of Topic
Objectives
Laparoscopic surgery provides clear visualization of surface anatomy but leaves critical subsurface structures hidden, increasing the risk of bile-duct injury1, incomplete tumor resection2 or ablation3, and other complications. Laparoscopic ultrasound (LUS) offers real-time visualization of vessels, ducts, and masses beneath the surface. However, its clinical adoption remains limited due to its steep learning curve and the challenge of spatially integrating ultrasound and laparoscopic images4. Navigation-enhanced LUS has shown promise for improving spatial awareness through image fusion and augmented visualization5.
We present a novel LUS probe that integrates two complementary tracking technologies – electromagnetic (EMT) and vision-based tracking – to provide accurate, real-time localization of the probe tip within the surgical field. Designed to work with Terason ultrasound systems, this probe aims to simplify LUS navigation, shorten the learning curve, and enable broader use of intraoperative ultrasound in laparoscopic surgery.
Description of Technology and Methods
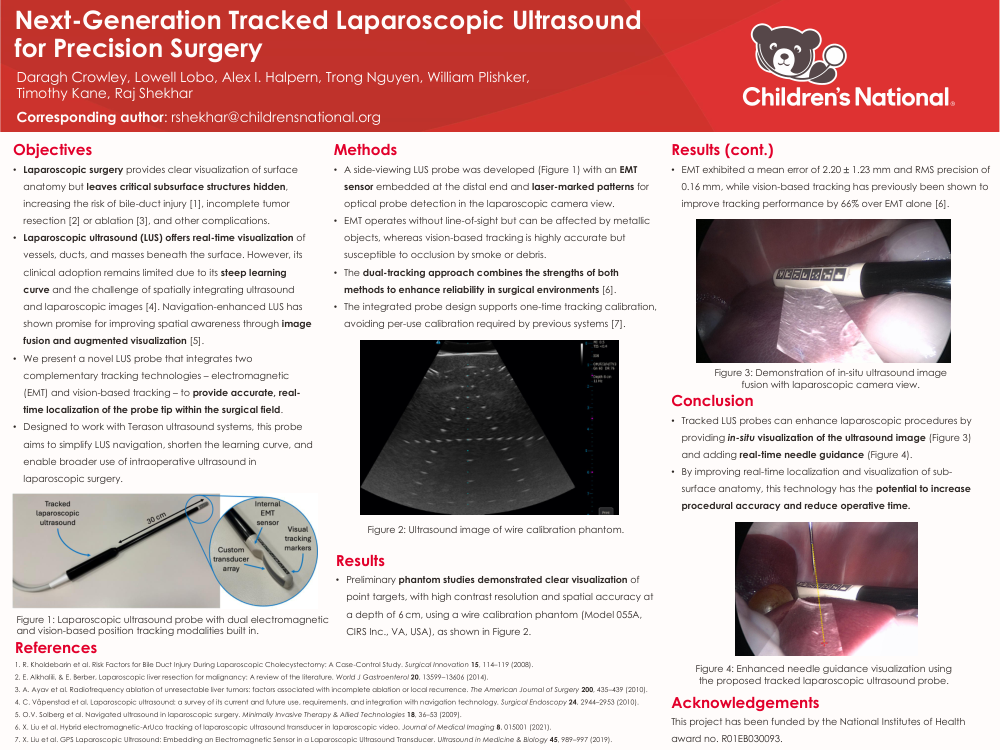
A side-viewing LUS probe was developed (Figure 1) with an EMT sensor embedded at the distal end and laser-marked patterns for optical probe detection in the laparoscopic camera view. EMT operates without line-of-sight but can be affected by metallic objects, whereas vision-based tracking is highly accurate but susceptible to occlusion by smoke or debris. The dual-tracking approach combines the strengths of both methods to enhance reliability in surgical environments6. The integrated probe design supports one-time tracking calibration, avoiding per-use calibration required by previous systems7.
Results
Preliminary phantom studies demonstrated clear visualization of point targets, with high contrast resolution and spatial accuracy at a depth of 6 cm, using a wire calibration phantom (Model 055A, CIRS Inc., VA, USA), as shown in Figure 2.
Both EMT and vision-based tracking operated reliably across multiple orientations and positions, with combined tracking improving overall navigation accuracy and usability. EMT exhibited a mean error of 2.20 ± 1.23 mm and RMS precision of 0.16 mm, while vision-based tracking has previously been shown to improve tracking performance by 66% over EMT alone6.
Conclusion
Tracked LUS probes can enhance laparoscopic procedures, but prior work has been limited to research settings. The tracked LUS probe presented here introduces a clinically ready device that bridges the gap between research prototypes and OR use. By improving real-time localization and visualization of sub-surface anatomy, this technology has the potential to increase procedural accuracy, reduce operative time, and expand adoption of LUS in clinical practice.